Projects
Research Projects
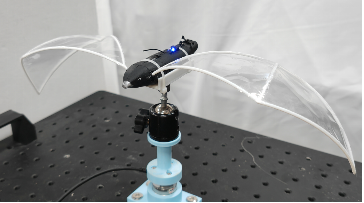
Spherical Linkages as Limbs in Flapping-Wing Robots
Designed planar, spherical, and Bennett 4-bar linkage wings; combined ANSYS Fluent simulation, force-sensor experiments, and neural-network models to find lift-optimal designs.
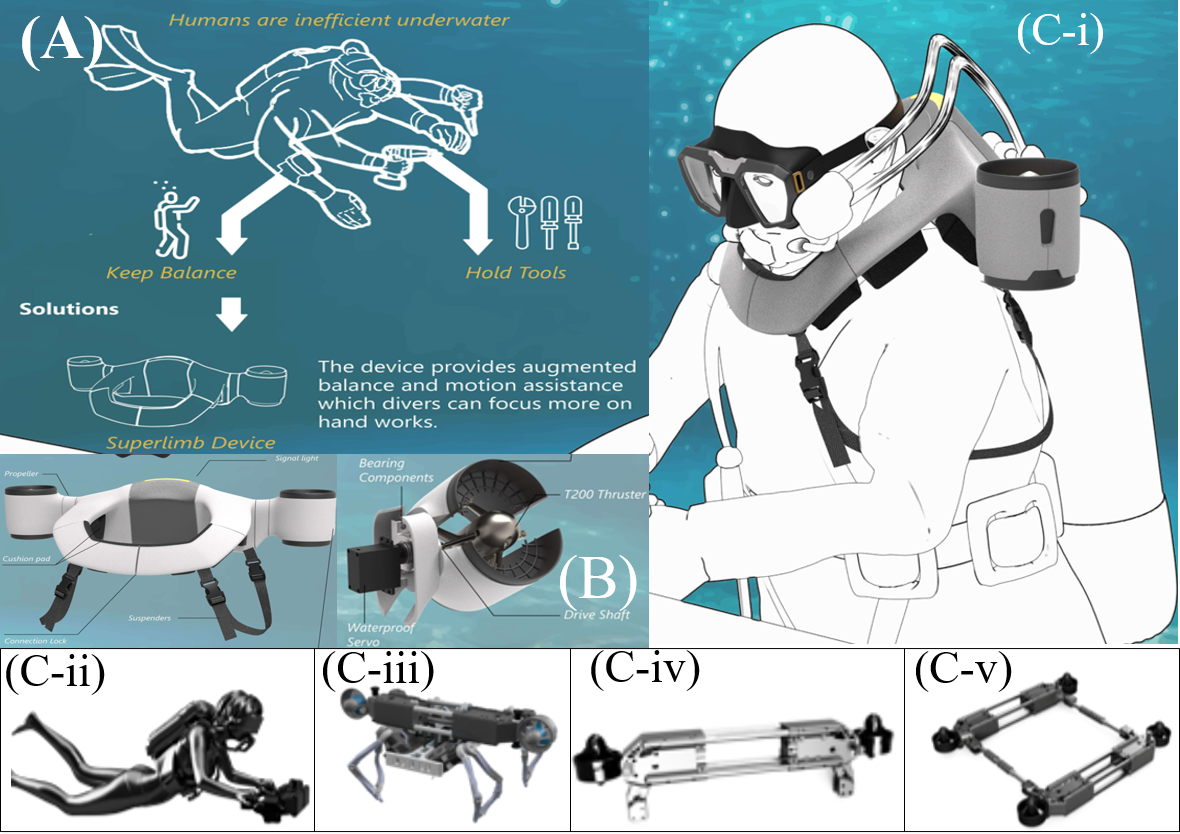
'Kunyi' – Underwater Reconfigurable Robot
Force analysis and verification of shaft components; First Prize at the 15th International Robot & Simulation Technology Competition.
Course Projects
CS7785 Final – Vision-based Sign Following
Course Grade: A